Emergency: same day
For a line-down motor, where the fault and parts allow. WhatsApp us before you send it so the bench is kept free.
Since 2000 · 3,000+ customers
Encoder and feedback repair · India
We repair, replace, align and reprogram servo motor feedback devices: incremental and serial absolute encoders, resolvers and Hall sensors, across more than 40 motor brands. Each device is tested on a universal multi-brand feedback platform, aligned to the rotor, proved in a run test, and returned with a printed report showing counts, angles and status bits.
Send a photo of the nameplate first. We confirm whether the motor is repairable, and the quote, the same working day.
For a line-down motor, where the fault and parts allow. WhatsApp us before you send it so the bench is kept free.
Repair, encoder alignment and test, counted from the day the motor reaches the bench and the quote is approved.
Full repair, encoder alignment, run test under load and a printed test report.
Fault found before anything is opened. Cable, connector, LED, board, battery circuit and memory faults repaired.
Commutation set to the rotor and checked at every pole pair.
OpenMotor data read, backed up, and written to a new encoder.
OpenMatching new or refurbished encoder sourced, fitted, aligned and programmed.
OpenWinding and signal checks, alignment, memory boards on Bosch and Indramat motors.
OpenHall board repair or replacement and 60° or 120° alignment.
OpenThese are the checks that appear on your test report. Values are typical; each device is set to its maker's specification.
| Check | What we look for | Typical result |
|---|---|---|
| Supply voltage | Encoder powered at its rated level, current draw normal | 5 V for most; about 7 to 8 V for Hiperface and Indramat digital; ±15 V for older Hall and tach boards |
| Serial data link | Position data received continuously, no communication errors while turning | Receiving, no dropouts |
| Counts per revolution | Count changes by the rated amount every turn, over four or more turns in each direction | For example 65,536 on a Fanuc αi A64, 131,072 on a Tamagawa TS5667, 262,144 on a Mitsubishi OBA18 |
| Stuck bits | Every position bit changes state within one revolution | None stuck |
| Quadrature (incremental) | B to A phase and A and B pulse symmetry | 90° and 180°, usually within ±22° |
| Index pulse (Z) | One clean pulse per turn at the same shaft position | 1 per revolution |
| Commutation tracks | U V W, C1 to C8 or C and D signals switch at the right electrical angles | Edges 60° or 120° apart as the motor requires |
| Electrical angle at rotor lock | Rotor locked with DC across the windings, angle read at every pole pair | Same reading at each lock position, matched to the motor maker's offset |
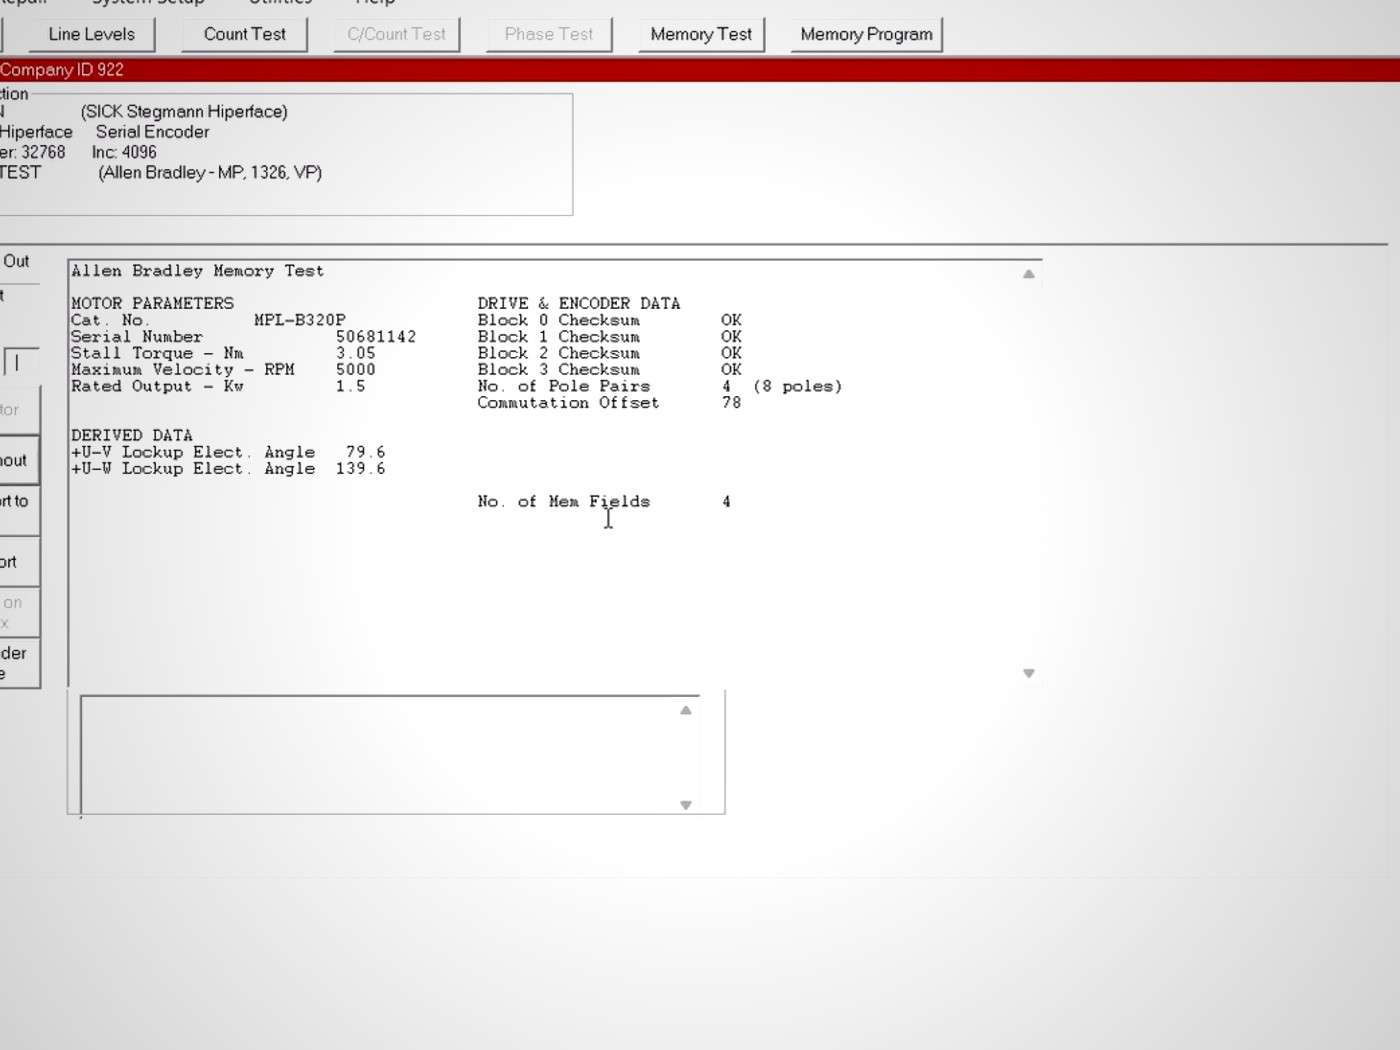
| Encoder memory | Motor data block present, checksum valid, data matches the nameplate | Checksums OK; reprogrammed when a new encoder is fitted |
| Status bits | Internal error, battery, overheat and multi-turn flags | All OK; battery flag tested by removing the battery |
| Resolver | Excitation, sine and cosine levels, vector level, angle without dead spots | Excitation set between 1 and 20 kHz, 2 to 3 V; clean waveforms |
| Run test | Motor run on a universal drive using the repaired feedback | Smooth in both directions, normal current |
| Feedback type | Encoder examples | Motors it is found on |
|---|---|---|
| Incremental ABZ with UVW | Renco RHS21D, RCH20, N-2300 to 5600; BEI H25; Hengstler F14; Nemicon; Eltra EH, EF80; Baumer BHF; Tamagawa incremental | Allen-Bradley TL, Y and MPL-H, Kollmorgen AKM and Goldline, Parker MPP and MPJ, Baldor BSM and M4500, Lafert, Reliance |
| Incremental 1 Vpp with sine and cosine commutation | Heidenhain ERN1387, ERN1381, ERN1326, RON350, ROD320, ROD426, ROD1424 | Siemens 1FT6 and 1FT5, Lust and Stromag FIP/FHP, Fadal and Baldor |
| Yaskawa C-channel and 12 or 15-bit absolute | UTOPH-81AWF, UTOPH-81AUS, UTOPI, 8,192 to 32,768 counts | Yaskawa SGM, SGMG, SGMS and USAEE, Allen-Bradley 8500 |
| Fanuc serial Pulsecoder | A, B, B2, C, α I8/A8/I64/A64/1000A, αi I64i/A64i/1000iA, β I32B/A32B/I64B/A64B/A128i | Fanuc α, αi, β and βi servo motors, robot motors, spindle sensors |
| Mitsubishi serial | OBE12, OBA13, OSA14, OAH14B, OHE4096, OBA/OSA17, OBA/OSA18, OSA/OSE104, 105 and 253 | HC-MF, HC-PQ, HC-KFS, HC-SFS, HF series, HA series, robot motors |
| Tamagawa serial | TS5643, TS5645, TS5647, TS5648, TS5667, TS5668, TS5669, TS5778, TS5781, MFE0017, MFE2500 | Panasonic MSMA, MSMD and Minas A, Toshiba and Shibaura, Nachi, Shinko and Kobelco robots, Rexroth MSM |
| Sanyo Denki and Sumtak serial | E03007758, E07B111335, E07B151103, E10B171103, R11G4113A, R11ABS, AEC/AEM and REC/REM 2048 | Sanyo Denki P, Q and R series, Nachi, Meiden |
| Heidenhain EnDat | ECN1313, EQN1325, ECI1118, EQI1130, ECI1317, EQI1329, ECN125 | Siemens 1FK7 and 1FT7, B&R 8LS and 8MS, Rexroth MSK, Kollmorgen, Baldor, Stober, AMK, Control Techniques Unimotor |
| SICK Stegmann Hiperface | SKS36, SKM36, SRS50/60, SRM50/60, SCS/SCM60/70, SNS50/60, SEL/SEK37 and 52 | Allen-Bradley MPL, MPF, MPS, 1326AB and H series, Rexroth MSK, Elau, Fagor, Schneider BMH, Baumüller, SEW DFS and CFM, Lenze MDXK |
| SSI and BiSS | Stegmann AG100 and AG661, Hengstler/Unico 319-663, EQN1325 SSI, BiSS AD36 | Indramat MAC, Stromag, MTS, Ultract |
| Indramat digital | ECN212, EQN224, ECN413, EQN425, ECN1313, EQN1325 (DSF/HSF), SCS70 | Indramat MDD, MHD, MKD and MKE, 2AD spindle |
| Kawasaki serial | H20/M21, HE-02 | Kawasaki robots, Sanyo Denki BL Super |
| Resolver | Single and multi-speed resolvers, Tamagawa and Sonder SMR | Allen-Bradley MPL and 1326AB, Bosch SR, Indramat MKD/MKE/MDD, Kollmorgen Goldline and 6SM, Parker, Baldor BSM, SEW DFS, Lenze MDFK |
| Hall sensors with tachometer | Hall boards, DC tach | Siemens 1FT5, Indramat MAC, Baldor, ABB PH, SEM HD and HJ, Kollmorgen Seidel SM56, BLDC and EV motors |
EnDat ECN/EQN/ECI/EQI, ERN and ROD incremental, Indramat digital.
OpenHiperface SKS, SKM, SRS, SRM, SCS, SNS, SEL, SEK; SSI AG100.
OpenTS5643 to TS5781, MFE0017, MFE2500.
Openα, αi, β and βi serial Pulsecoders, spindle sensors.
OpenOBA, OSA, OSE, OBE, OHE serial encoders.
OpenC-channel, UTOPH, UTOPI, 12 and 15-bit absolute.
OpenE07B, E10B, R11, AEC/AEM, H20/M21, HE-02.
OpenRenco, BEI, Hengstler, Nemicon, Eltra, Baumer.
OpenSend the nameplate and encoder label.
Fault recorded before opening.
Board, cable or encoder.
Rotor offset and motor data.
Run test, printed report.
We repair when the fault is in parts that can be changed without affecting the optical or magnetic measurement: connectors, cables, power supply components, line drivers, the battery circuit or corrupted memory.
We replace the encoder when the code disc is cracked or contaminated beyond cleaning, the sensor chip has failed, or the bearing has let the disc touch the read head. A replacement is always aligned and, where the motor stores data in the encoder, programmed with that motor's data before it leaves us.
Many can be repaired. Faults in the cable, connector, LED, board components, battery circuit or memory are repairable. If the code disc or sensor is damaged, we fit a replacement encoder and then align and program it so the motor works on your existing drive.
Yes, if the encoder is aligned to the rotor and, on motors that store data in the encoder, the motor data block is written back. We do both and run the motor before dispatch.
Setting the encoder's commutation position to the rotor's magnetic poles so the drive switches current at the right moment. A misaligned encoder makes a motor run hot, rough or weak, or trip on overcurrent.
No. We test the encoder and run the motor on a universal test platform, so you do not have to send the drive. Send the drive too if you suspect it.
Emergency jobs the same day where the fault and parts allow; urgent in 3 working days; standard in 7 working days. Imported encoders are quoted with their own timeline.
Not always. Many absolute encoders lose the multi-turn count when the backup battery runs down. Replacing the battery and homing the axis often fixes it. If the alarm returns, the encoder or its battery circuit needs checking.
Yes. We test resolvers for winding faults and signal quality and align them, and we repair and realign Hall sensor boards on BLDC and EV motors.
A printed test report: counts per revolution, phase and commutation readings, electrical angle at lock, memory and status results, and the run test.
A step-by-step check with a DC supply and a meter.
OpenHow each works and how each fails.
OpenWhat the common alarms usually point to.
OpenFor motor makers and machine builders.
OpenPrintable one-page sheets from our bench. More on the resources page.
Encoder families, interfaces, counts per revolution and the motors they sit on: Fanuc pulsecoders (alpha A64, A1000), Mitsubishi OBA/OSA, Yaskawa UTOPH, Tamagawa, Heidenhain ECN/EQN/ERN and SICK SKS/SRS/SRM.
PDF · 2 pages · 8 KB · free, no sign-up
Download PDFCommon encoder and feedback alarms on Fanuc, Yaskawa, Mitsubishi and Siemens drives, what each usually points to, and what to check on the cable and connector first.
PDF · 1 page · 4 KB · free, no sign-up
Download PDFWhat to record before removing an encoder, the order of checks after refitting it, and the readings that tell you commutation is right before the motor goes back on the machine.
PDF · 1 page · 4 KB · free, no sign-up
Download PDFA clear photo of the motor nameplate and, if the cover is off, the encoder label is enough to start. We reply with whether it can be repaired and a quote.
Our team replies by email or WhatsApp, usually the same working day. For a line-down motor, WhatsApp +91 97866 22233.