Emergency: same day
For a line-down motor, where the fault and parts allow. WhatsApp us before you send it so the bench is kept free.
Since 2000 · 3,000+ customers
Encoder memory · Read and program
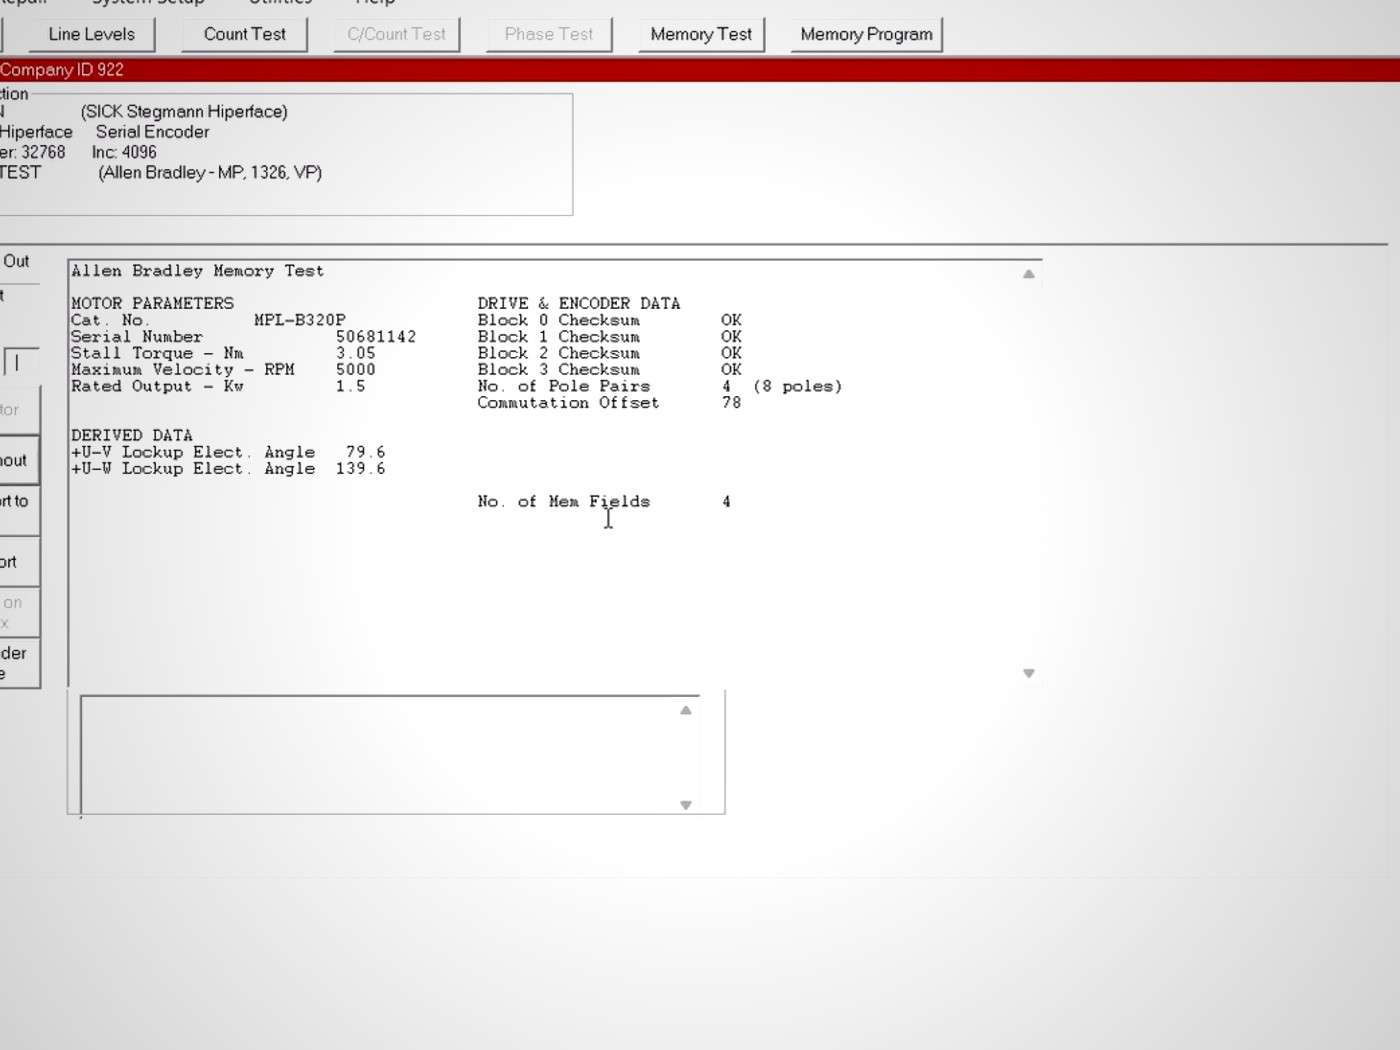
Many servo motors keep their own data inside the encoder: motor type, serial number, pole count and the commutation offset. If that memory is lost, or a new encoder is fitted, the drive will not run the motor. We read and save the memory before work starts, check its checksums, and write the correct motor data to a replacement encoder.
Send a photo of the nameplate first. We confirm whether the motor is repairable, and the quote, the same working day.
For a line-down motor, where the fault and parts allow. WhatsApp us before you send it so the bench is kept free.
Repair, encoder alignment and test, counted from the day the motor reaches the bench and the quote is approved.
Full repair, encoder alignment, run test under load and a printed test report.
| Motor family | Encoder | Memory format |
|---|---|---|
| Allen-Bradley MPL, MPF, MPS, 1326AB, 8720 spindle | SICK Stegmann SKS36, SKM36, SRS50/60, SRM50/60 | Allen-Bradley motor data on Hiperface |
| B&R 8LS and 8MS | Heidenhain EQI1317, EQI1327, EQI1329, ECN1313, EQN1325 | B&R motor data on EnDat |
| Bosch Rexroth MSK | Heidenhain ECN1313, EQN1325 or Stegmann SKS36, SKM36 | Rexroth data on EnDat or Hiperface |
| Bosch Rexroth / Indramat SF | Heidenhain EQI1317, EQI1329, ECN1313, EQN1325 | SF data on EnDat |
| Bosch Rexroth / Indramat SR | Resolver with memory board | Data on the resolver memory board |
| Indramat MDD, MHD, MKD, MKE | Heidenhain ECN212, EQN224, ECN413, EQN425, ECN1313, EQN1325 or Stegmann SCS70; resolver boards on MKD/MKE | Indramat digital (I²C) format |
| Bosch Rexroth MSM | Tamagawa MFE0017 | Rexroth data on Tamagawa serial |
| Elau SH and SM | Stegmann SKS36, SKM36, SRS, SRM | Elau data on Hiperface |
| Fagor FXM and FKM | Stegmann SNS | Fagor data on Hiperface |
| Schneider Electric BMH | Stegmann SKS36, SKM36, SEK37, SEL37 | Schneider data on Hiperface |
| Berger Lahr SER | Stegmann SRS | Berger Lahr data on Hiperface |
Read and store the memory file.
Check each block and checksum.
Lock the rotor, find the true offset.
Program motor data and offset.
Memory test, then run test.
The drive reads no motor data and usually shows a motor identification or encoder data alarm. The motor will not be enabled until the data is restored.
Yes, if the old encoder still communicates. We save its memory file first. If it does not, we rebuild the data for that motor model and set the commutation offset by measurement.
No. The data written matches the motor's own nameplate and model, so the drive sees the same motor it was commissioned with.
Related. On these motors part of the alignment lives in memory as an offset. We measure the true rotor position, then write the offset, then confirm it with a run test.
Printable one-page sheets from our bench. More on the resources page.
Encoder families, interfaces, counts per revolution and the motors they sit on: Fanuc pulsecoders (alpha A64, A1000), Mitsubishi OBA/OSA, Yaskawa UTOPH, Tamagawa, Heidenhain ECN/EQN/ERN and SICK SKS/SRS/SRM.
PDF · 2 pages · 8 KB · free, no sign-up
Download PDFWhat to record before removing an encoder, the order of checks after refitting it, and the readings that tell you commutation is right before the motor goes back on the machine.
PDF · 1 page · 4 KB · free, no sign-up
Download PDFA clear photo of the motor nameplate and, if the cover is off, the encoder label is enough to start. We reply with whether it can be repaired and a quote.
Our team replies by email or WhatsApp, usually the same working day. For a line-down motor, WhatsApp +91 97866 22233.